This content was written and submitted by the supplier. It has only been modified to comply with this publication’s space and style.
Automating the handling of fresh mozzarella requires a different approach from conventional food products. Its soft consistency and delicate surface require controlled handling throughout the process, particularly when products must be automatically positioned and loaded into packaging machines.
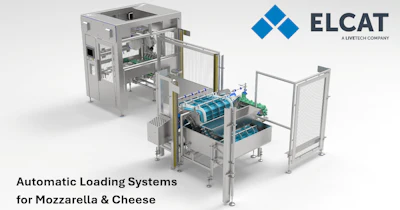
ELCAT Food Technology develops automatic mozzarella and cheese loading systems that integrate product receiving, elevation, distribution, positioning, robotic multi-pick handling and automatic loading into thermoforming machines.
Rather than adapting a standard loading system to the product, each solution is engineered around the characteristics of the cheese, the required pack configuration and the packaging process.
From Water Infeed to Automatic Handling
Fresh mozzarella can arrive directly from the production process through a water conveying channel, allowing the product to remain in water until the automated handling process begins.
A dedicated receiving system collects the incoming mozzarella, while a flighted elevator conveyor gently lifts the products from the water and transfers them toward the subsequent distribution stage.
From this point onward, the system progressively creates a controlled and organized product flow, preparing each mozzarella for automatic positioning and robotic handling.
Automatic Distribution and Positioning
After elevation, mozzarella portions are transferred individually onto a dedicated conveyor and directed toward the positioning area.
A movable positioning system progressively distributes the incoming products into predefined pick positions, transforming products arriving one by one into an ordered group ready for robotic handling.
In one ELCAT configuration, four mozzarella portions are automatically positioned to create a repeatable four-product pick pattern for the subsequent loading cycle.
This allows the robotic operation to start from a controlled product arrangement rather than relying on manual grouping or positioning.
Gentle Multi-Pick Robotic Handling
Once the mozzarella portions are correctly positioned, a purpose-designed multi-pick gripper handles several products simultaneously.
The gripping concept is developed specifically around the soft and delicate consistency of fresh mozzarella, allowing the products to be transferred while minimizing unnecessary compression, deformation and manipulation.
By combining product-specific gripping technology with controlled positioning, the robotic system can perform repeatable multi-product pick cycles while maintaining the required handling conditions throughout the transfer.
Automatic Loading into Thermoforming Machines
The complete group is transferred directly to the thermoforming machine, where the robotic loading cycle is synchronized with the packaging process.
Multiple mozzarella portions are automatically loaded into the corresponding thermoformed cavities, providing accurate positioning and a controlled, repeatable loading pattern.
The process therefore connects product arrival from production directly with the packaging machine through one coordinated automation sequence.
One Integrated Mozzarella Loading Process
The complete ELCAT system combines water infeed, product elevation, distribution, positioning, robotic multi-pick handling and automatic loading into the thermoforming machine.
Each stage is engineered around the characteristics of fresh mozzarella and coordinated with the following operation, creating a continuous process from production to packaging while reducing manual product handling.
The same engineering approach can be adapted to other cheese products according to their shape, consistency, surface characteristics and packaging format.
Beyond Mozzarella: Product-Specific Cheese Handling
Different cheese products require different handling strategies. A soft fresh mozzarella cannot be conveyed, gripped and positioned in the same way as a more consistent cheese portion or block.
ELCAT Food Technology develops product-specific conveying, positioning, gripping and automatic loading solutions, selecting the handling concept according to the actual characteristics of the product and the requirements of the packaging process.
From delicate fresh cheese portions to more consistent cheese products, conveyors and robotic grippers can be purpose-designed and integrated with thermoforming or other packaging systems.